Full-stack & embedded engineer

Volga Can Karakus

I build agricultural robots end to end: firmware, computer vision, cloud pipelines and the apps on top.

Volga sitting in an orange-lit lounge under a glowing AWS sign

TerraSentia on a test plot, and me at AWS.

9+
years shipping agricultural robotics software
86k
lines of C# in a game I build alone
3
clouds behind one analytics pipeline
2
products founded and built solo

Nine years in the field with TerraSentia.

Senior Software Engineer, EarthSense · 2018 to 2026

I owned systems on an autonomous crop-scouting robot, from the firmware up through the cloud analytics that turn raw field collections into crop data.

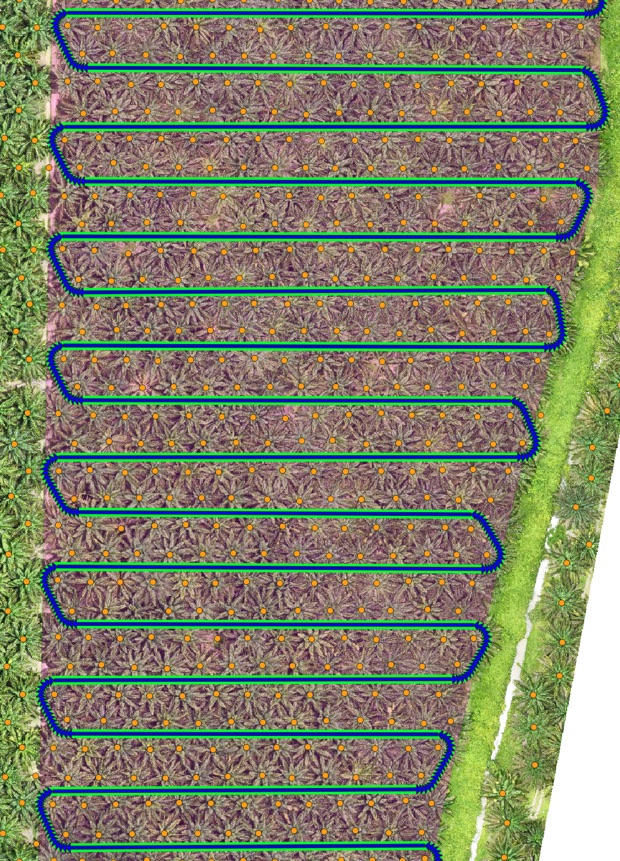
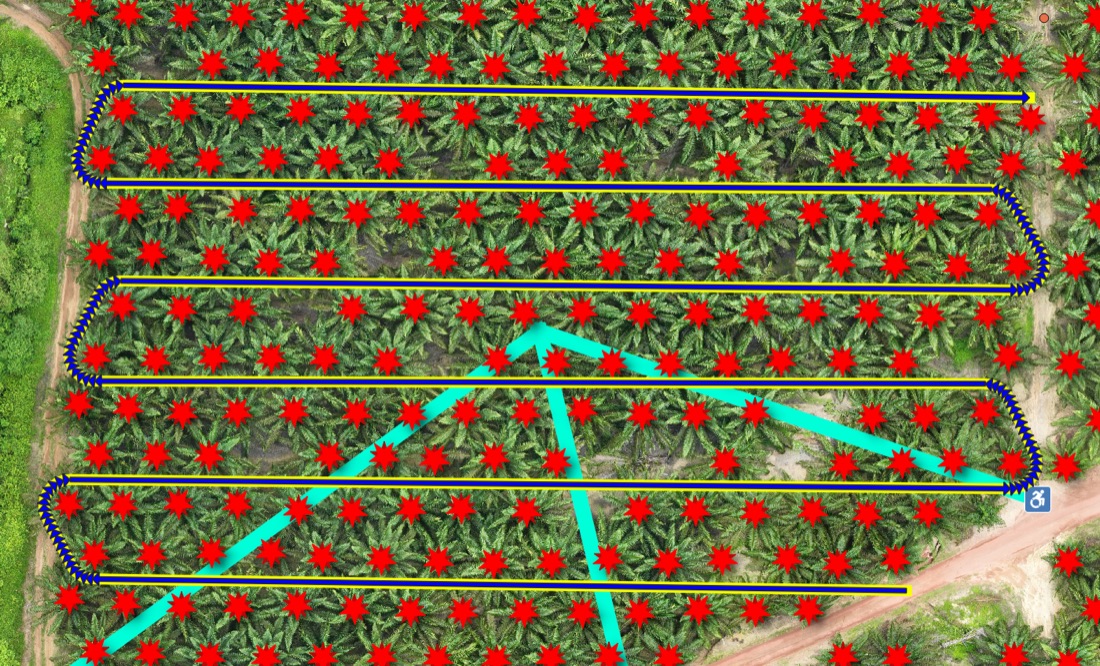
Aerial view of a palm plantation with detected trees marked in red and a serpentine robot route looping between the rows Aerial view of a tapering orchard block with detected tree centres and a generated back-and-forth route with rounded U-turns
Generated field routes: YOLOv8 finds the trees, the planner threads a serpentine path through the rows.
  1. 01

    Cloud analytics pipeline

    Containerized microservices on Azure Kubernetes that estimate crop height, LAI, width, stand count and point clouds, fed by a MongoDB change stream and a Redis job queue across AWS, Azure and GCP storage.

  2. 02

    LiDAR crop-height algorithm

    Polar-to-Cartesian conversion, left and right contour generation and percentile-based averaging, plus the internal Python libraries for odometry, camera projection and point clouds.

  3. 03

    Autonomous path generator

    Serpentine field routes built from YOLOv8-detected tree centres and field boundaries, with row clustering and curvature-constrained Bézier U-turns, exported as GeoJSON.

  4. 04

    Web teleoperation

    Real-time video and autonomous waypoint navigation over WebSockets and AWS Kinesis Video Streams, integrated with ROS2 Humble and shipped in Docker.

  5. 05

    Data-review web app

    SvelteKit on Firebase with a MongoDB Realm backend and Azure identity, used for plot alignment, video and LiDAR review, and launching pipelines.

  6. 06

    LoRa firmware and operator apps

    C++ LoRa firmware for Adafruit Feather M0 and custom SAMD21 modules on FreeRTOS, plus the Android apps operators use to drive the robots in the field.

Software Engineer (contract), Esit Electronik · 2025

Debugged a React Native telemetry app on Firebase, and built a YOLOv8 service that detects and counts Mediterranean fruit flies in trap imagery.

Things I build on my own time.

ShroomVerse · 2025 to present

An idle strategy game for iOS and Android.

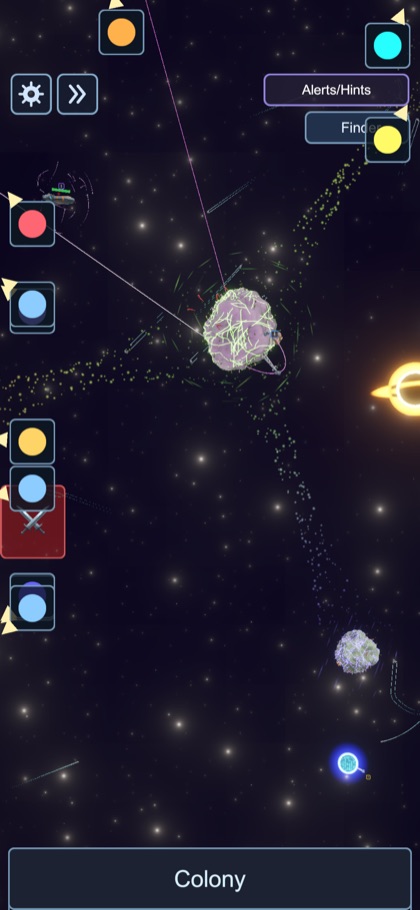
Planets rebuild from a single seed and shatter along Voronoi cells. The economy keeps running while you are away, replayed step by step so it can never drift from the live rules.

  • 86k lines of C# on Unity 6 URP
  • Five custom HLSL shaders
  • 69 unit tests on asynchronous combat
  • About 30 UI panels, all built in code

Eden · 2024 to present

A smart garden sensor.

ESP32 firmware for BLE setup, camera capture and moisture sensing, with a SwiftUI companion app on Supabase.

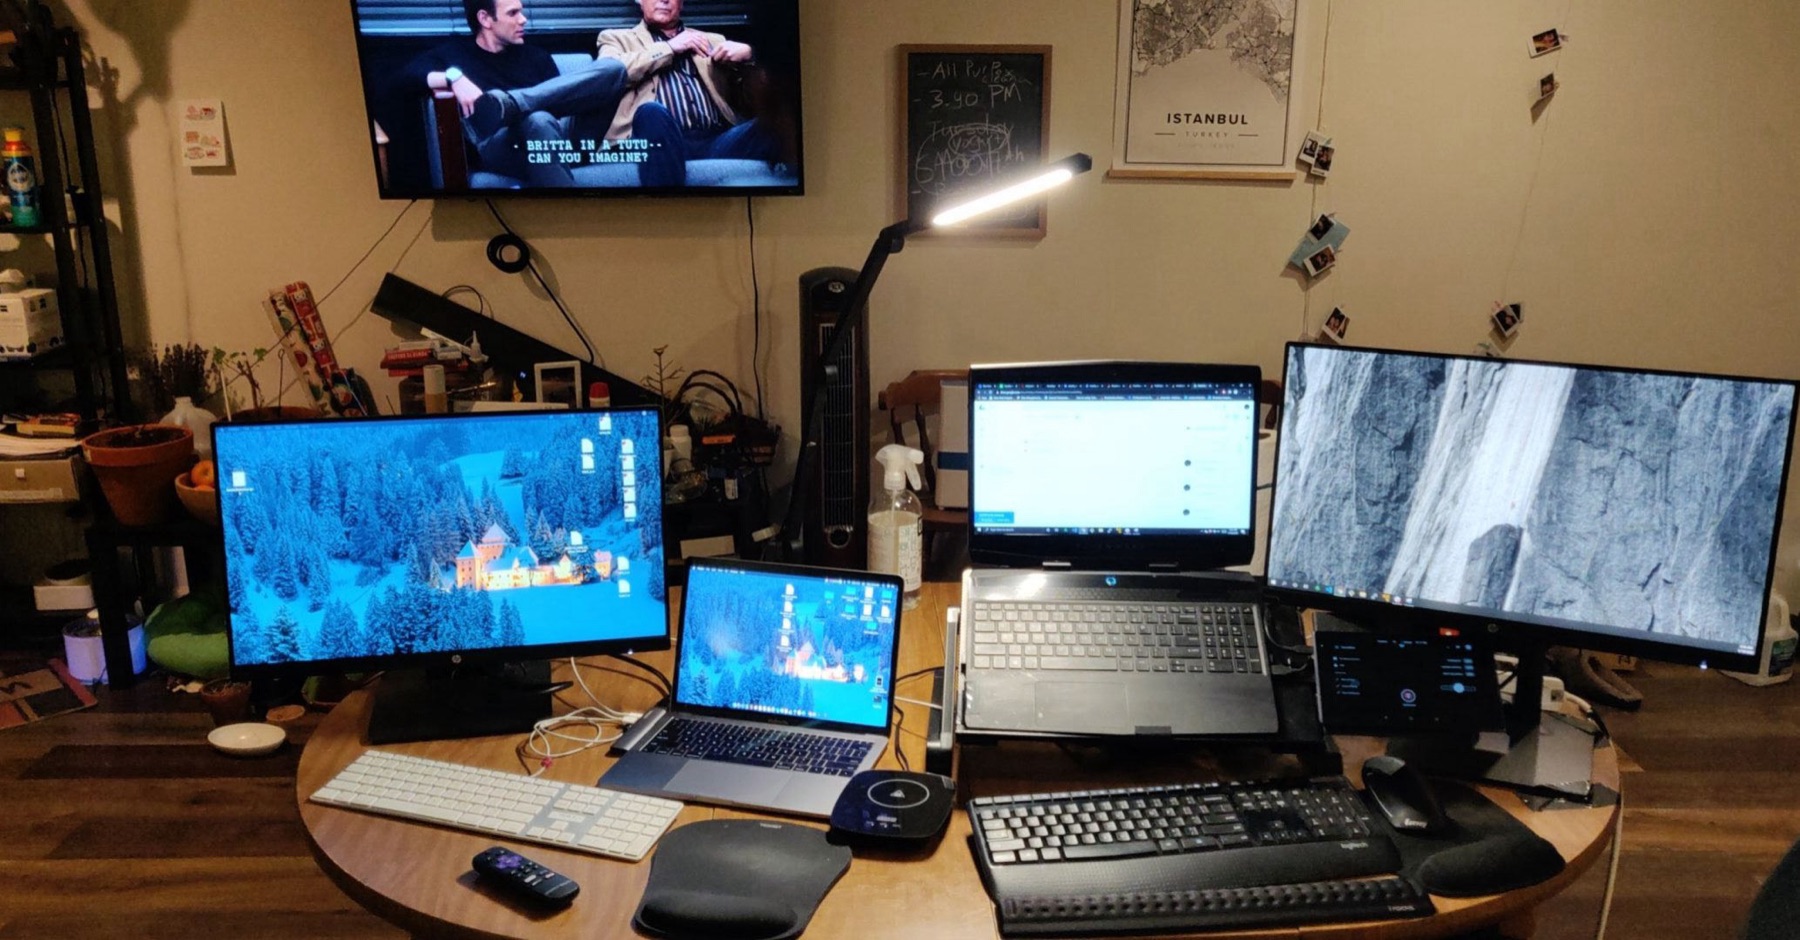
A home desk with four monitors, a laptop and two keyboards
Where the side projects happen.
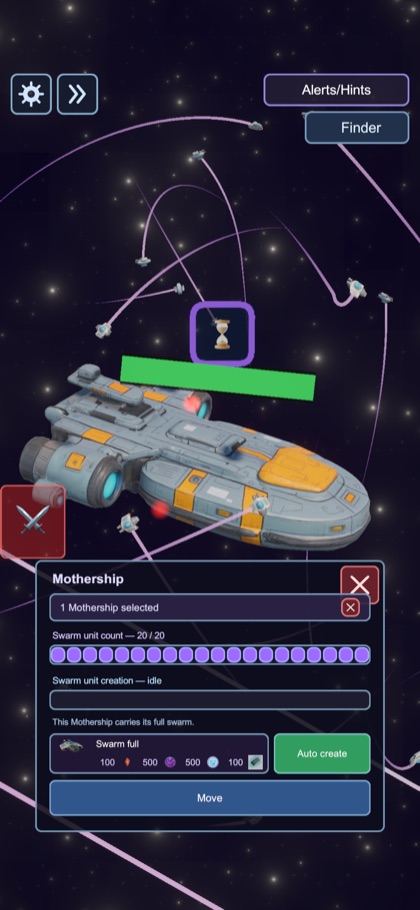
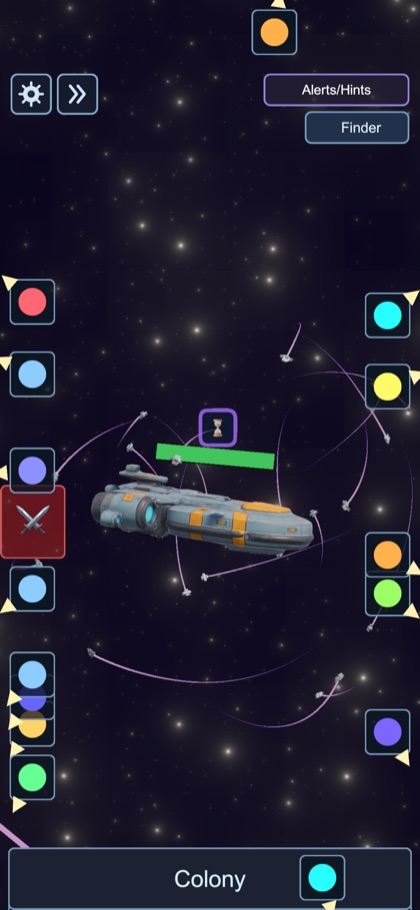
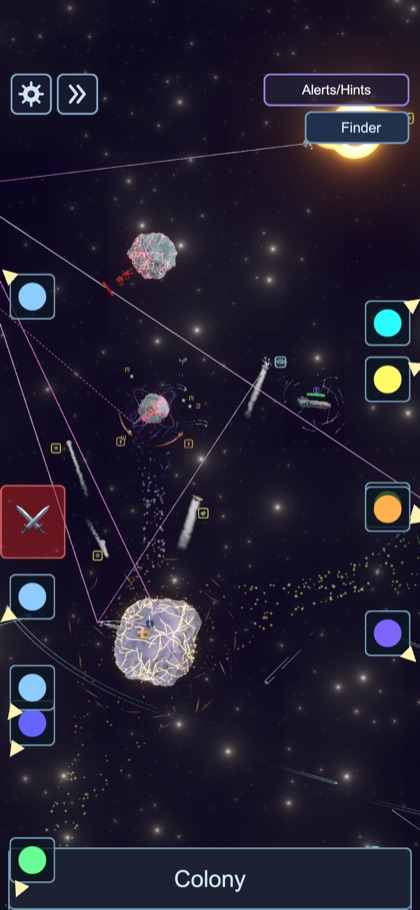
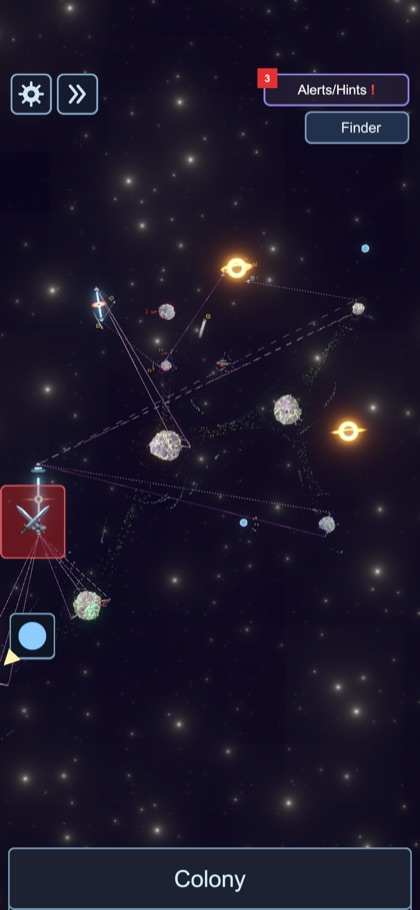
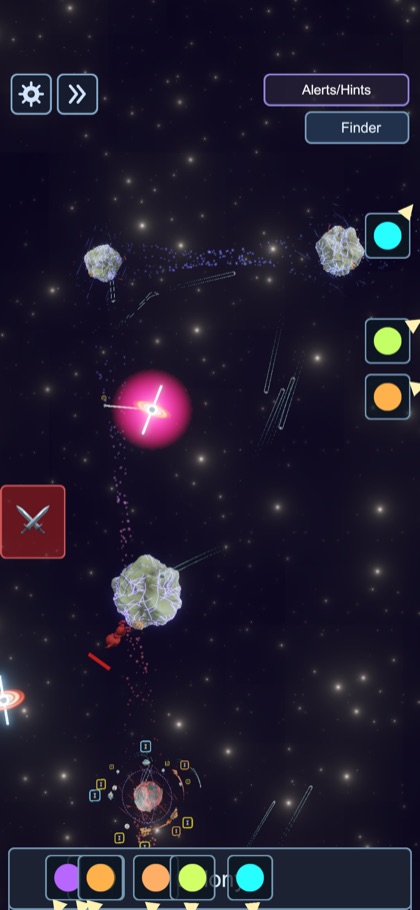
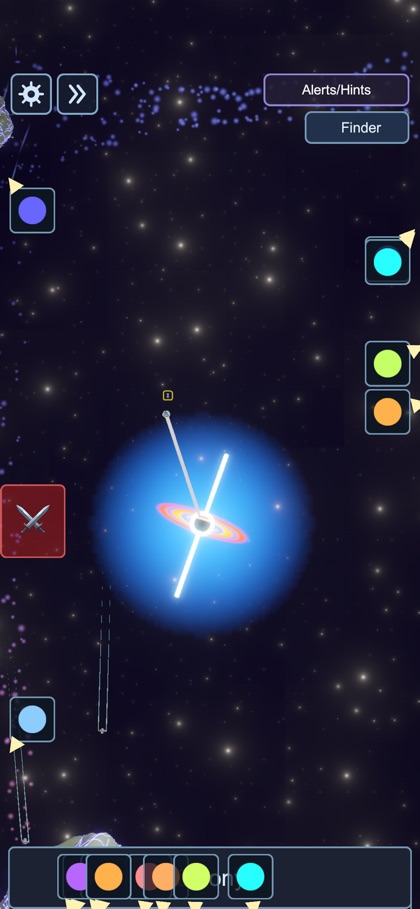
ShroomVerse colony view: a cratered asteroid planet in a starfield, with resource markers along the screen edges A selected mothership with its panel open, showing the swarm unit count and an auto create button The mothership cruising between orbit paths with a build timer above it Two small planets linked by supply lines with ships in transit The star map with three new alerts waiting in the Alerts panel A glowing pink star beside an asteroid planet, with ships gathering nearby A bright blue black hole with an accretion disk and ships orbiting around it
ShroomVerse on iPhone. Planets grow from a single seed, and every panel is built in code.

Selected projects

  • Robot Data WebappJWT-authenticated dashboard charting robot field metrics. Node, React, MongoDB.
  • Companion Logging WebLocal Dockerized site with AES-256-GCM credential encryption over robot collections.
  • John Deere Tango automationSenior capstone: an Android controller for an automated mower, presented to John Deere engineers.
The toolkit.

Languages
Python, C#, TypeScript, JavaScript, C/C++, Java, Swift, Dart, SQL, Bash
Cloud & DevOps
AWS, Azure AKS, GCP, Docker, Kubernetes, Firebase
Backend & Data
Node, Express, Flask, Meteor, MongoDB, Redis, REST, WebSockets
Frontend
React, Svelte, SvelteKit, Vite, D3
Mobile
SwiftUI, React Native, Expo, Flutter, Android
Robotics & ML
ROS2 Humble, LiDAR, OpenCV, YOLOv8, NumPy, SciPy, GIS
Embedded
PlatformIO, ESP32, SAMD21, FreeRTOS, BLE, LoRa
Game dev
Unity 6 URP, HLSL, procedural meshes, Unity Test Framework
AI-assisted dev
Claude Code: agent loops, custom skills, subagents, hooks

Off the clock, I chase light.

Macro, travel, and whatever the sun happens to be doing. Same patience as debugging a robot in a cornfield, better lighting.

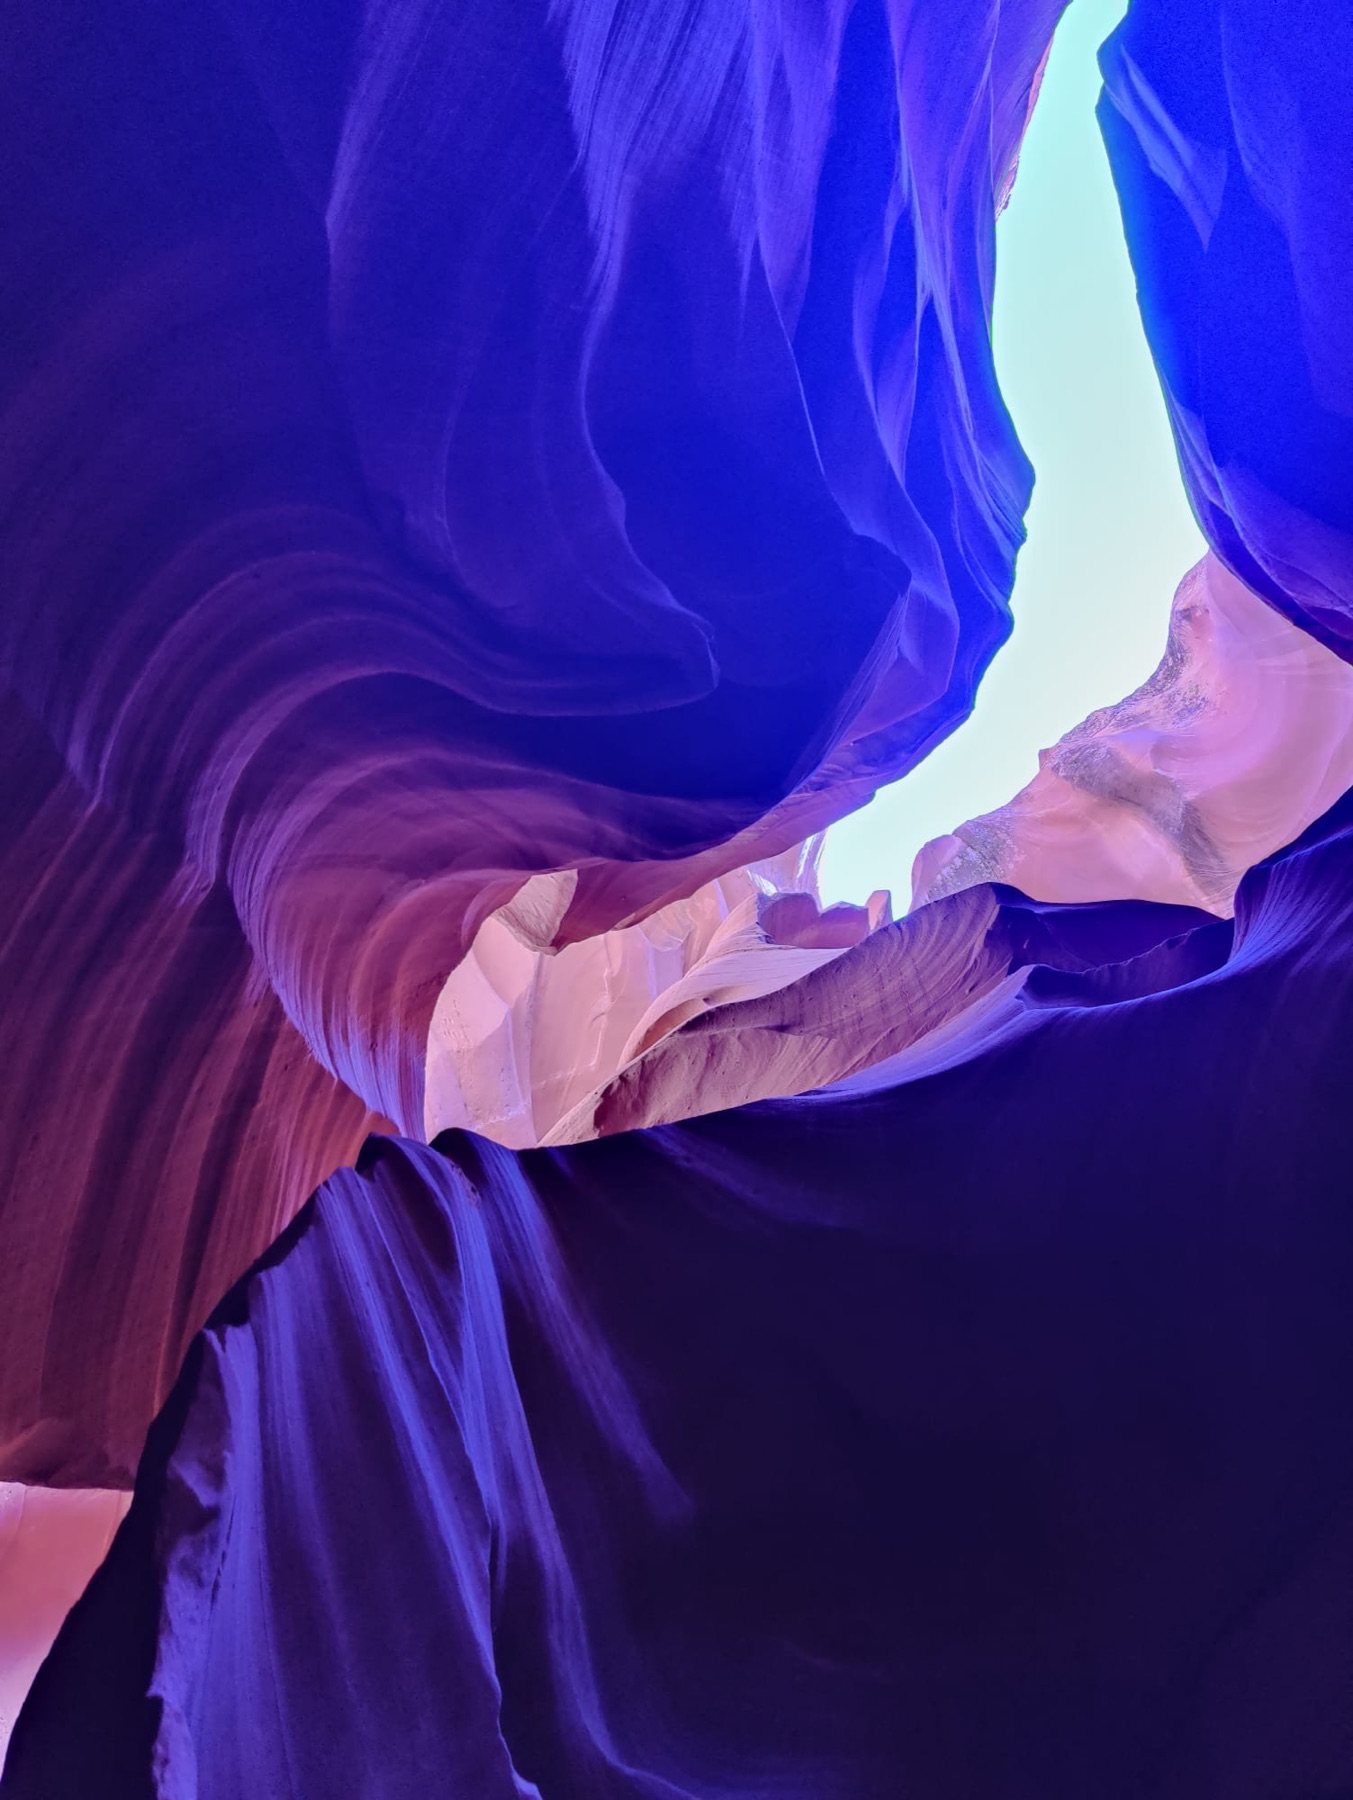
Violet sandstone walls curling up toward a sliver of sky in a slot canyon
Slot canyon
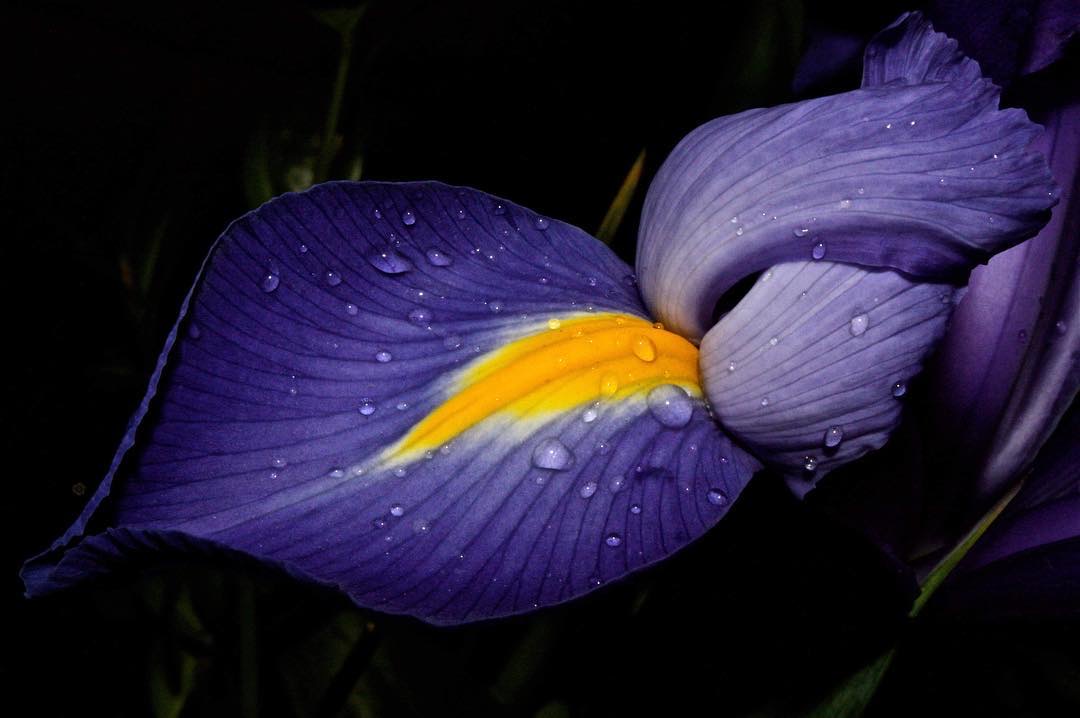
A violet iris petal with a yellow stripe, beaded with raindrops
Iris after rain
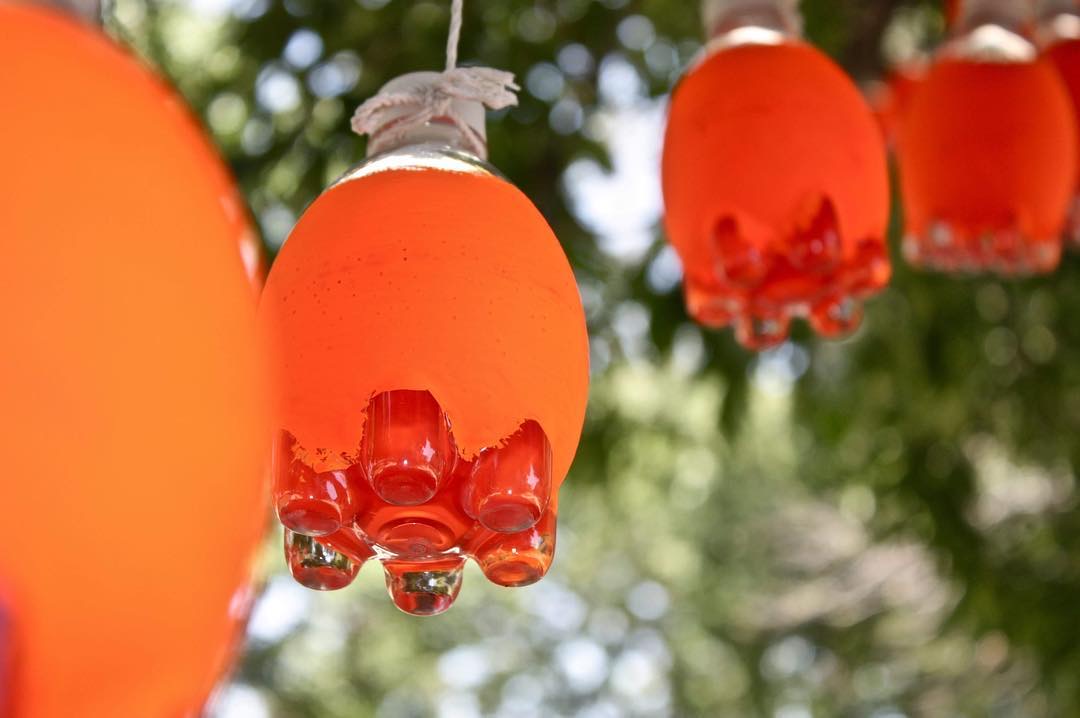
Orange glass lanterns hanging against blurred green trees
Lanterns
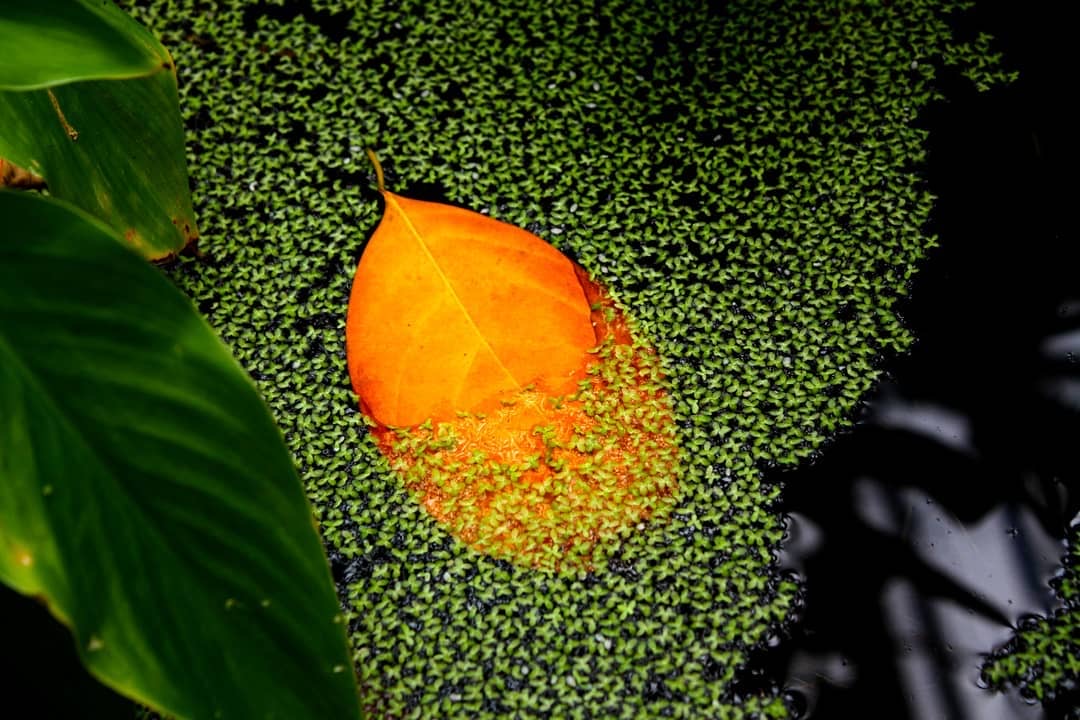
An orange leaf resting on a carpet of duckweed
Leaf on duckweed
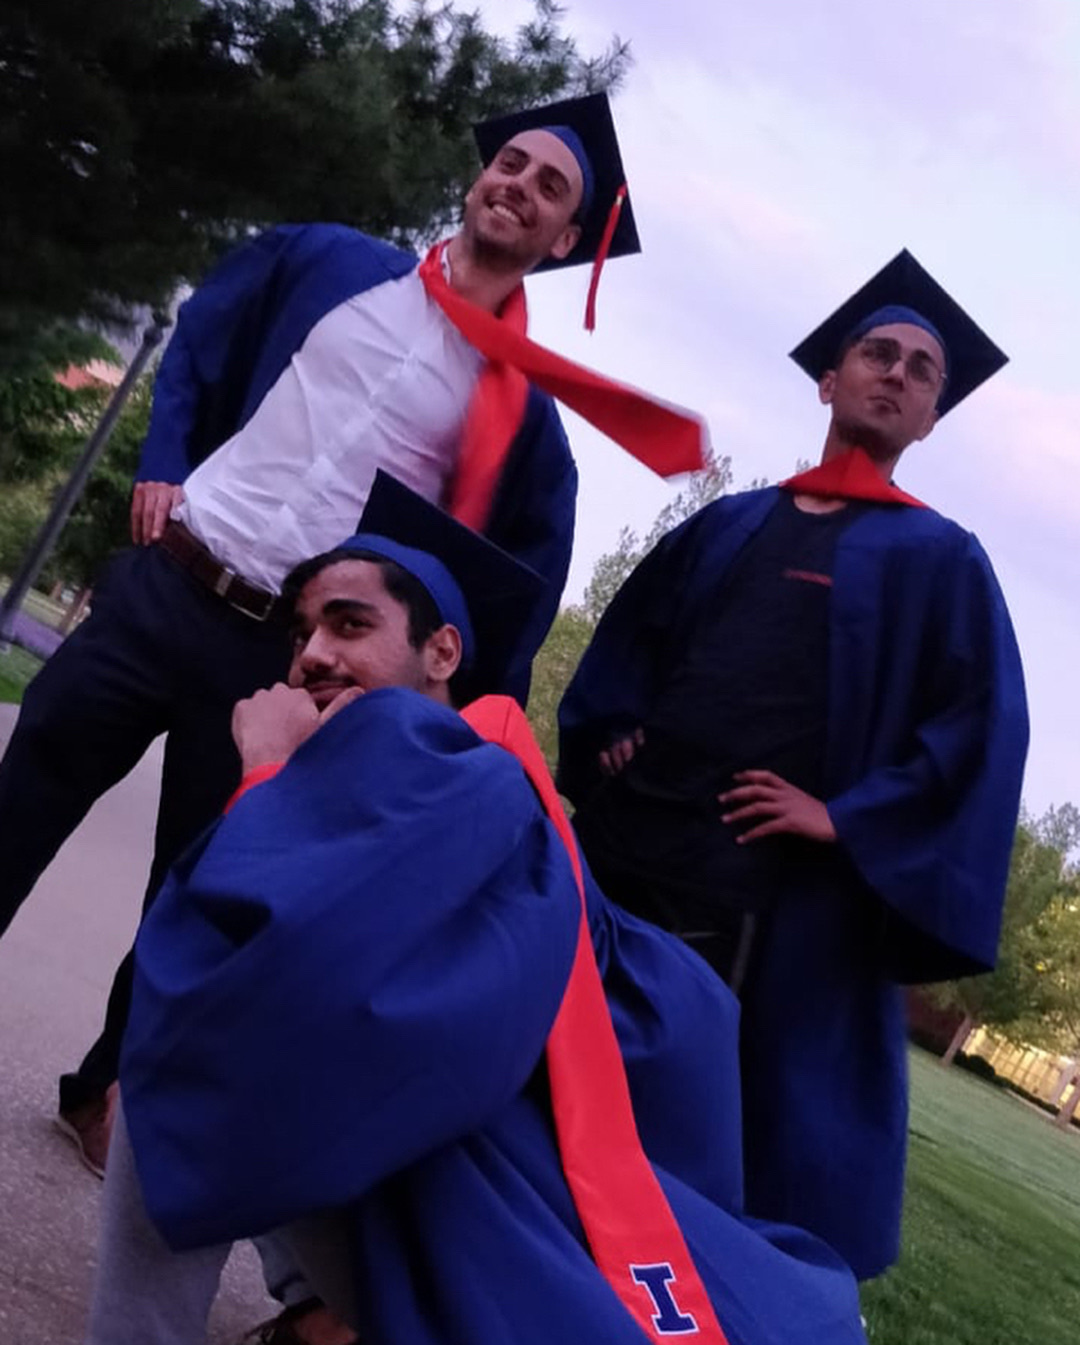
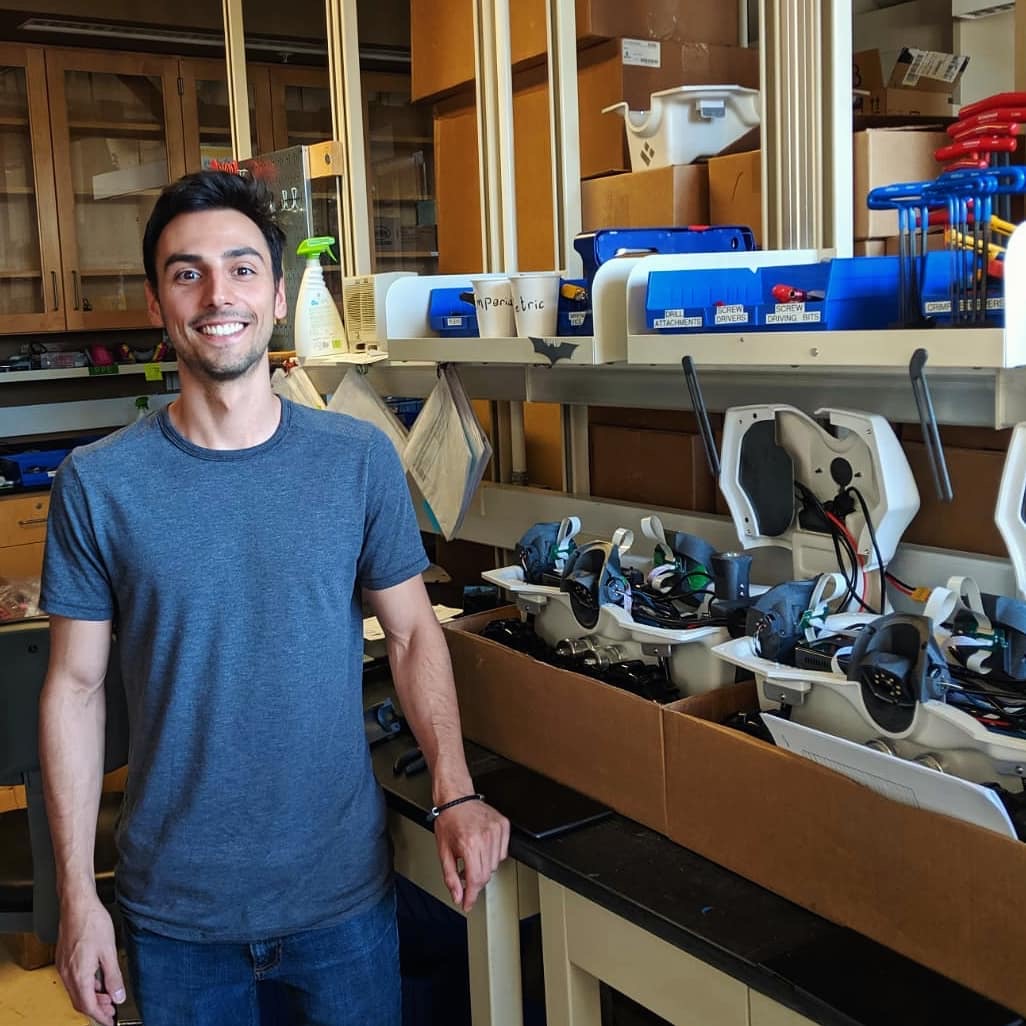
Volga and two friends in blue Illinois graduation gowns and caps A sunny rooftop terrace on the Illinois campus Volga smiling in a lab next to shelves of small field robots

Trained on tractors and compilers.

University of Illinois at Urbana-Champaign

B.S. Agricultural Off-Road Equipment Engineering, minor in Computer Science · 2018

Robotics, field sensing, embedded systems, AI, computer graphics and mechatronics. Teaching assistant for Embedded Systems and Dynamic Mechanics.

Lycée Pierre Loti d'Istanbul

French Baccalaureate, science specialization · 2013

Let's build something that leaves the lab.

volgacan@gmail.com
LieutenantChips

Based in Istanbul, Türkiye.